Projects
Selected projects.

Interactive Language-Guided Grasping in MuJoCo
2025VLM-Guided Target Grounding, 3D Grasping, and Execution
Built a VLM-guided manipulation pipeline that turns a user command into target grounding, masked 3D grasp inference, and executable UR5e pick-and-place behavior in Simulation of MuJoCo .
Visual GroundingRobotic ManipulationGraspNetMuJoCo
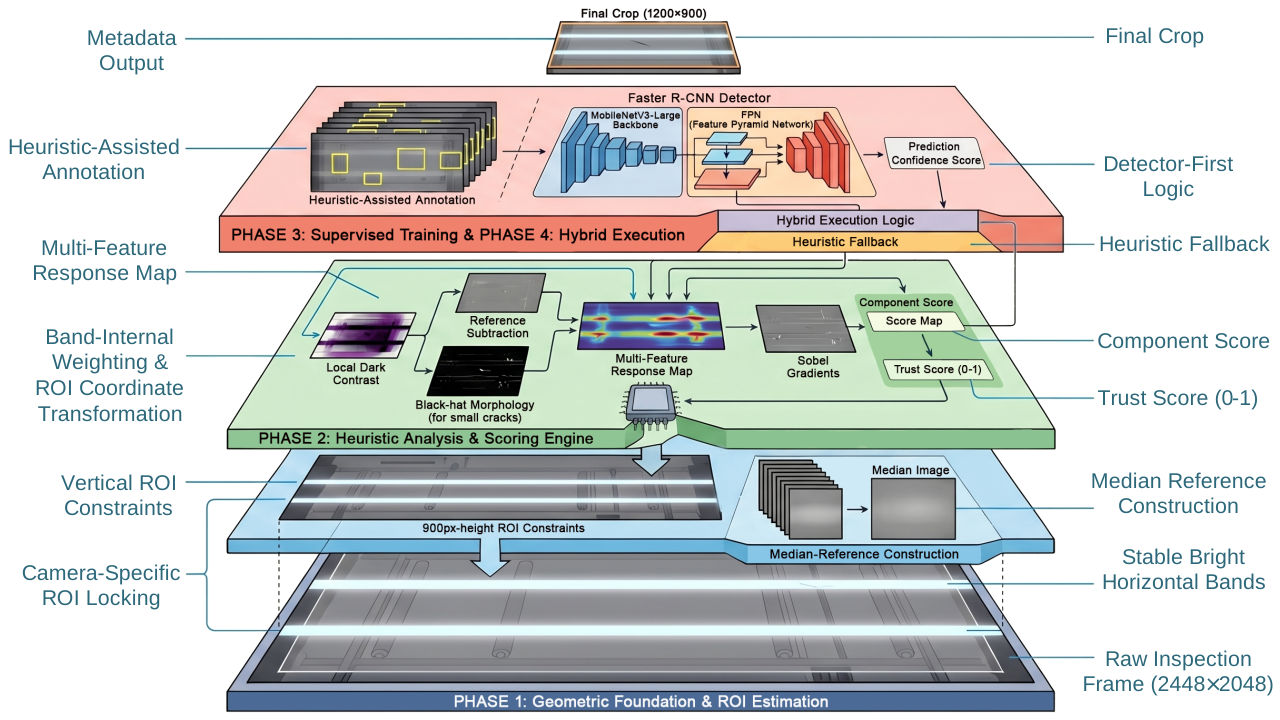
Glass Defect Detection and Fixed-Size Cropping
2025ROI-Based Industrial Vision for Reliable Defect Cropping
Designed a hybrid industrial-vision pipeline for one practical target: stable 1200x900 crops centered on glass defects.
Deep LearningComputer VisionFaster R-CNNROI-Based Detection