
About
I am an undergraduate student in Mechanical Engineering at the University of Leeds, enrolled in a joint program with Southwest Jiaotong University, advised by Prof. Zhichao You. During the Summer and Fall of 2026, I was a research intern at RIL Lab at The Hong Kong University of Science and Technology (Guangzhou), advised by Prof. Qiang Nie.
My current research interests lie in Robotic Manipulation and the intersection of Control Theory, Computer Vision, and Machine Learning. I am particularly focused on:
- Robot Learning: Developing robust policies for manipulation.
- Multimodal Learning: Leveraging diverse sensory data for better adaptive perception and interaction.
- VLA Models (Vision-Language-Action): Bridging the gap between high-level semantic understanding and low-level control.
Looking ahead, I hope to explore how embodied agents can achieve stronger generalization, better long-horizon decision-making, and more data-efficient learning in real-world settings, ideally without heavy reliance on large-scale robot data. I am particularly interested in directions that may help unify perception, reasoning, and control, such as multimodal policy learning, structured decision-making, and world models for embodied intelligence.
Publications
View All →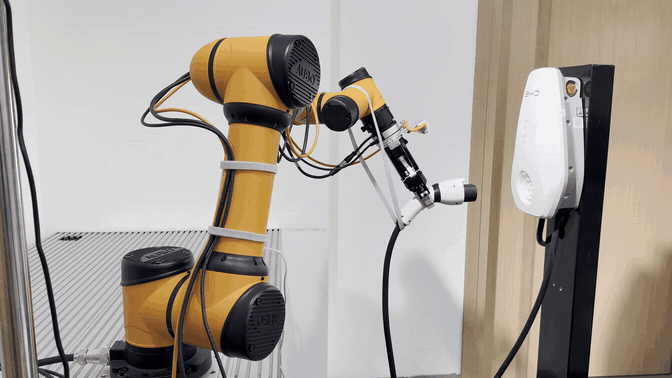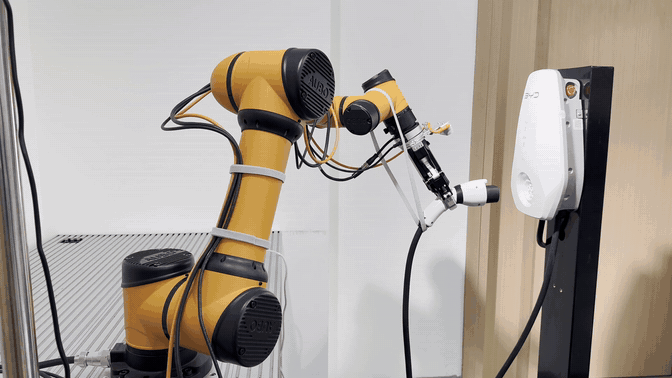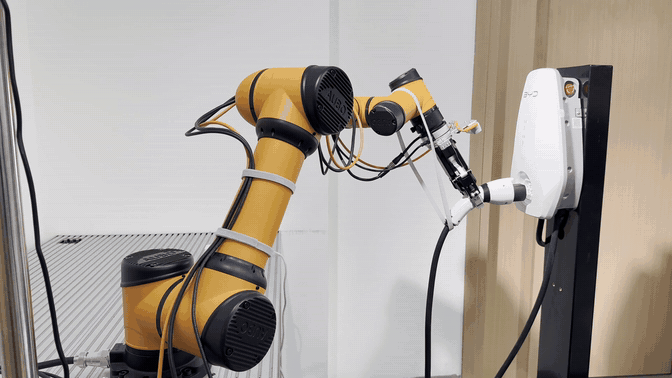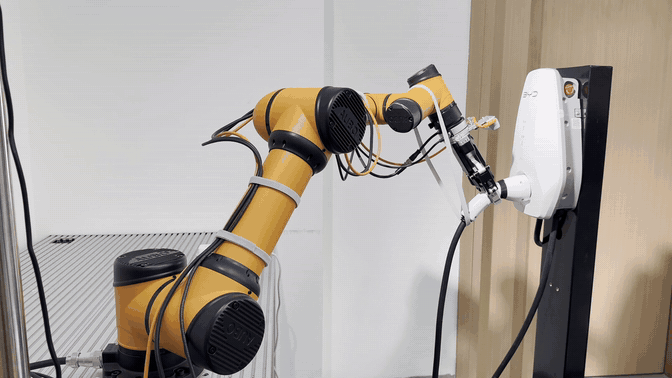
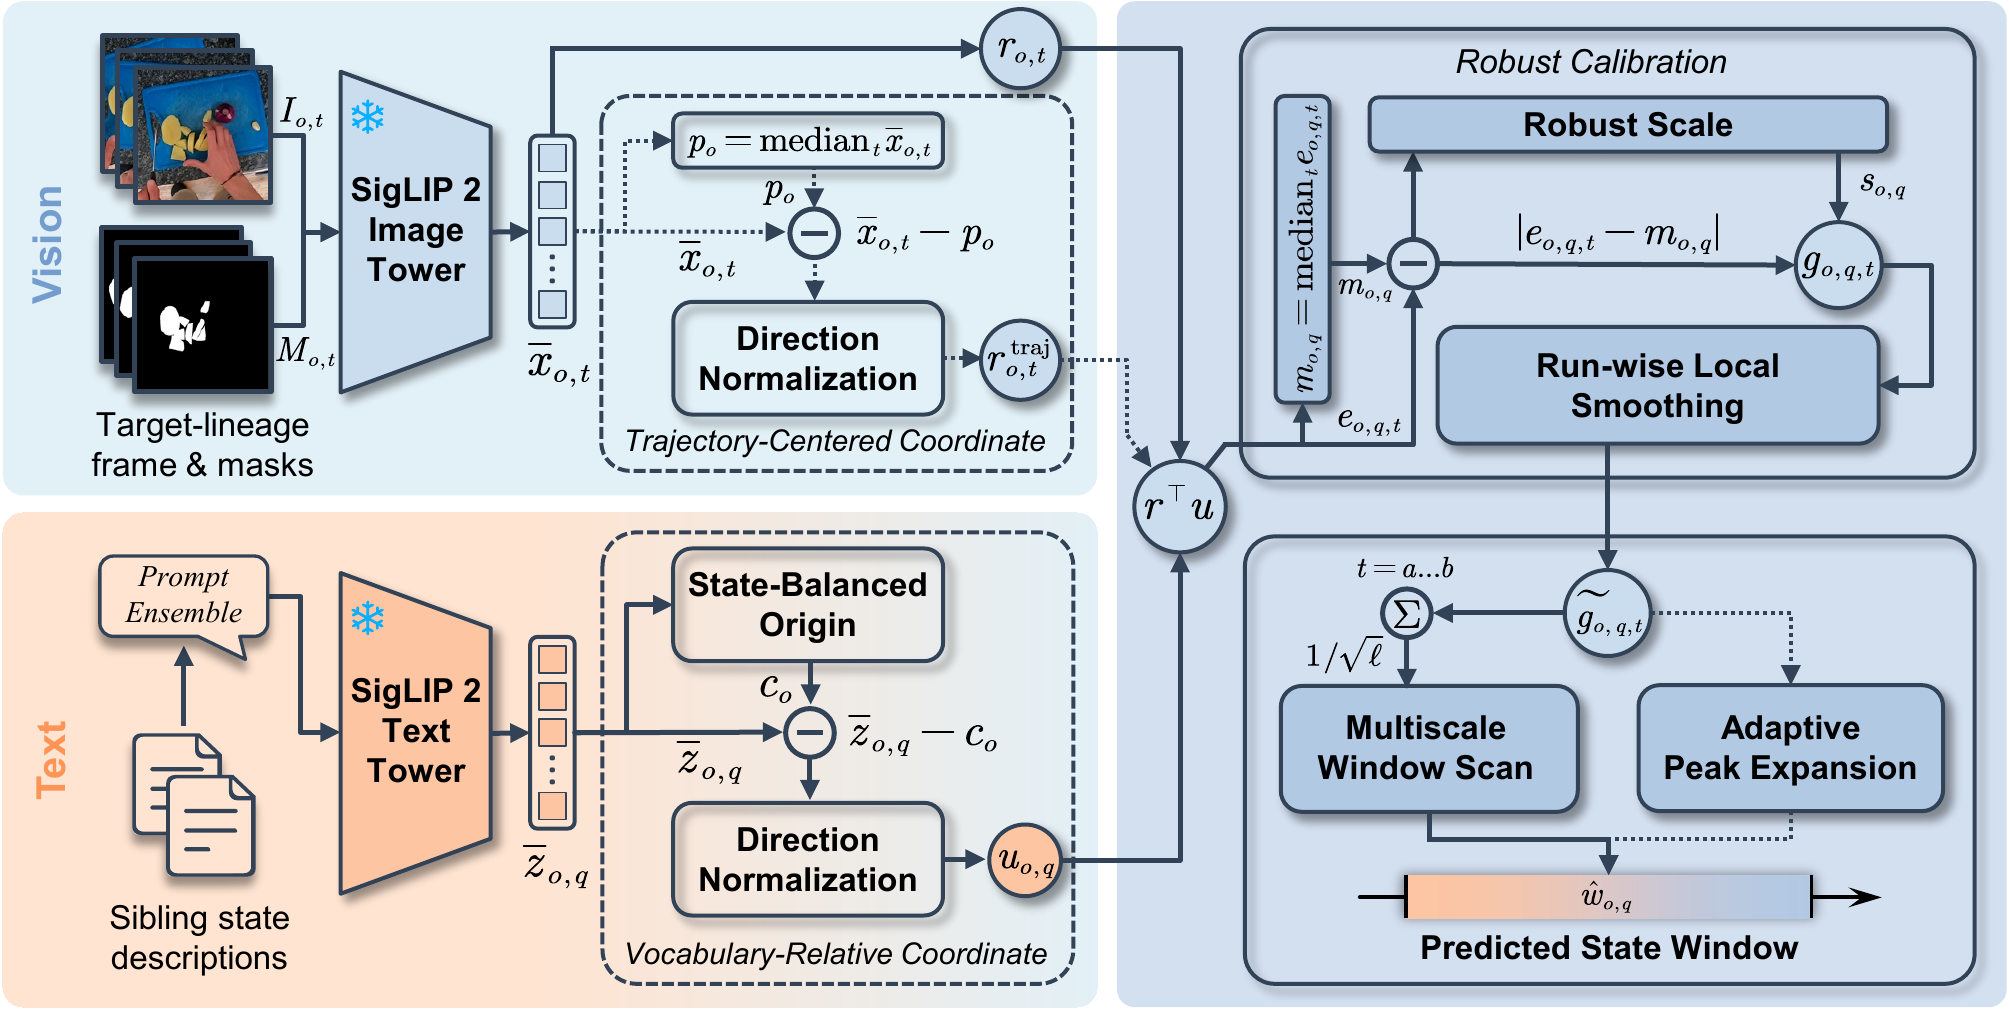
Projects

Interactive Language-Guided Grasping in MuJoCo
2025VLM-Guided Target Grounding, 3D Grasping, and Execution
Built a VLM-guided manipulation pipeline that turns a user command into target grounding, masked 3D grasp inference, and executable UR5e pick-and-place behavior in Simulation of MuJoCo .
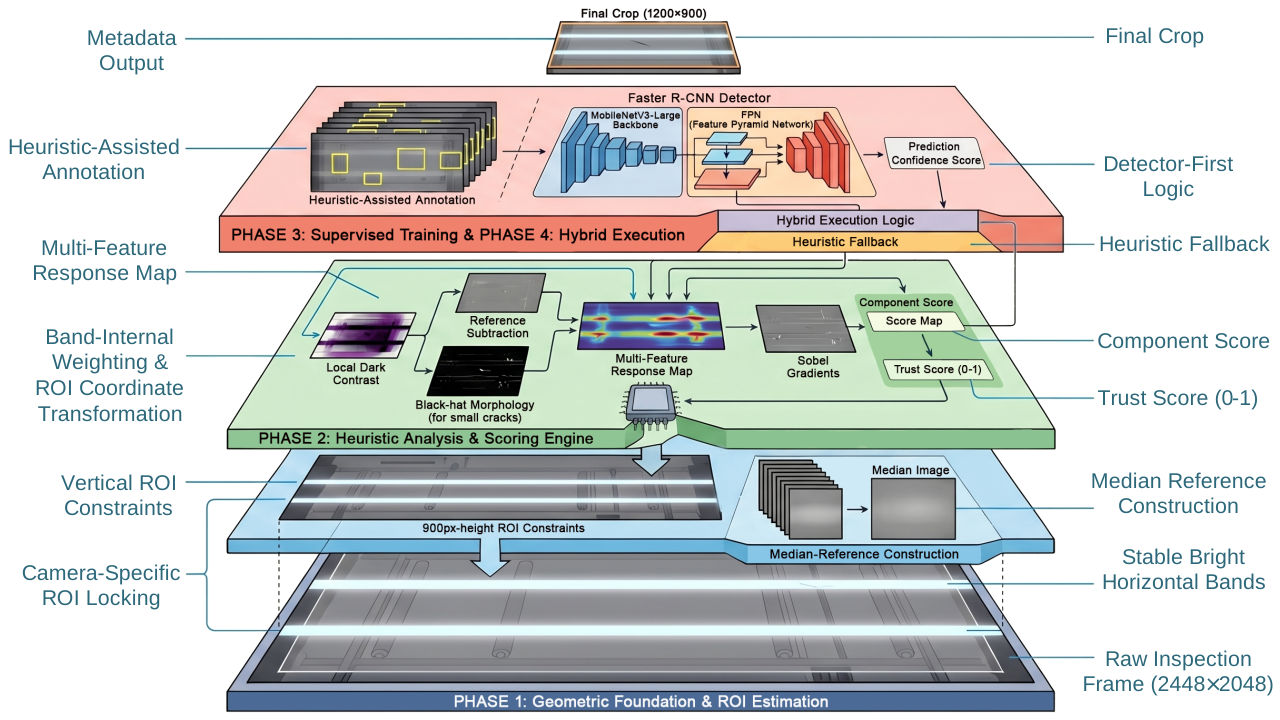
Glass Defect Detection and Fixed-Size Cropping
2025ROI-Based Industrial Vision for Reliable Defect Cropping
Designed a hybrid industrial-vision pipeline for one practical target: stable 1200x900 crops centered on glass defects.
News
The Glass Defect Detection and Fixed-Size Cropping project has been open-sourced.